PolyUAS: Quadcopter Gimbal Mount
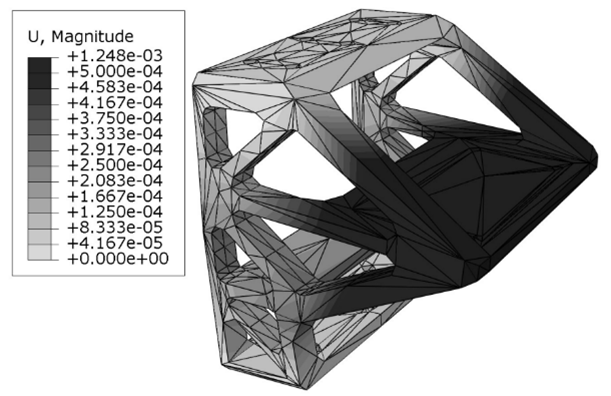
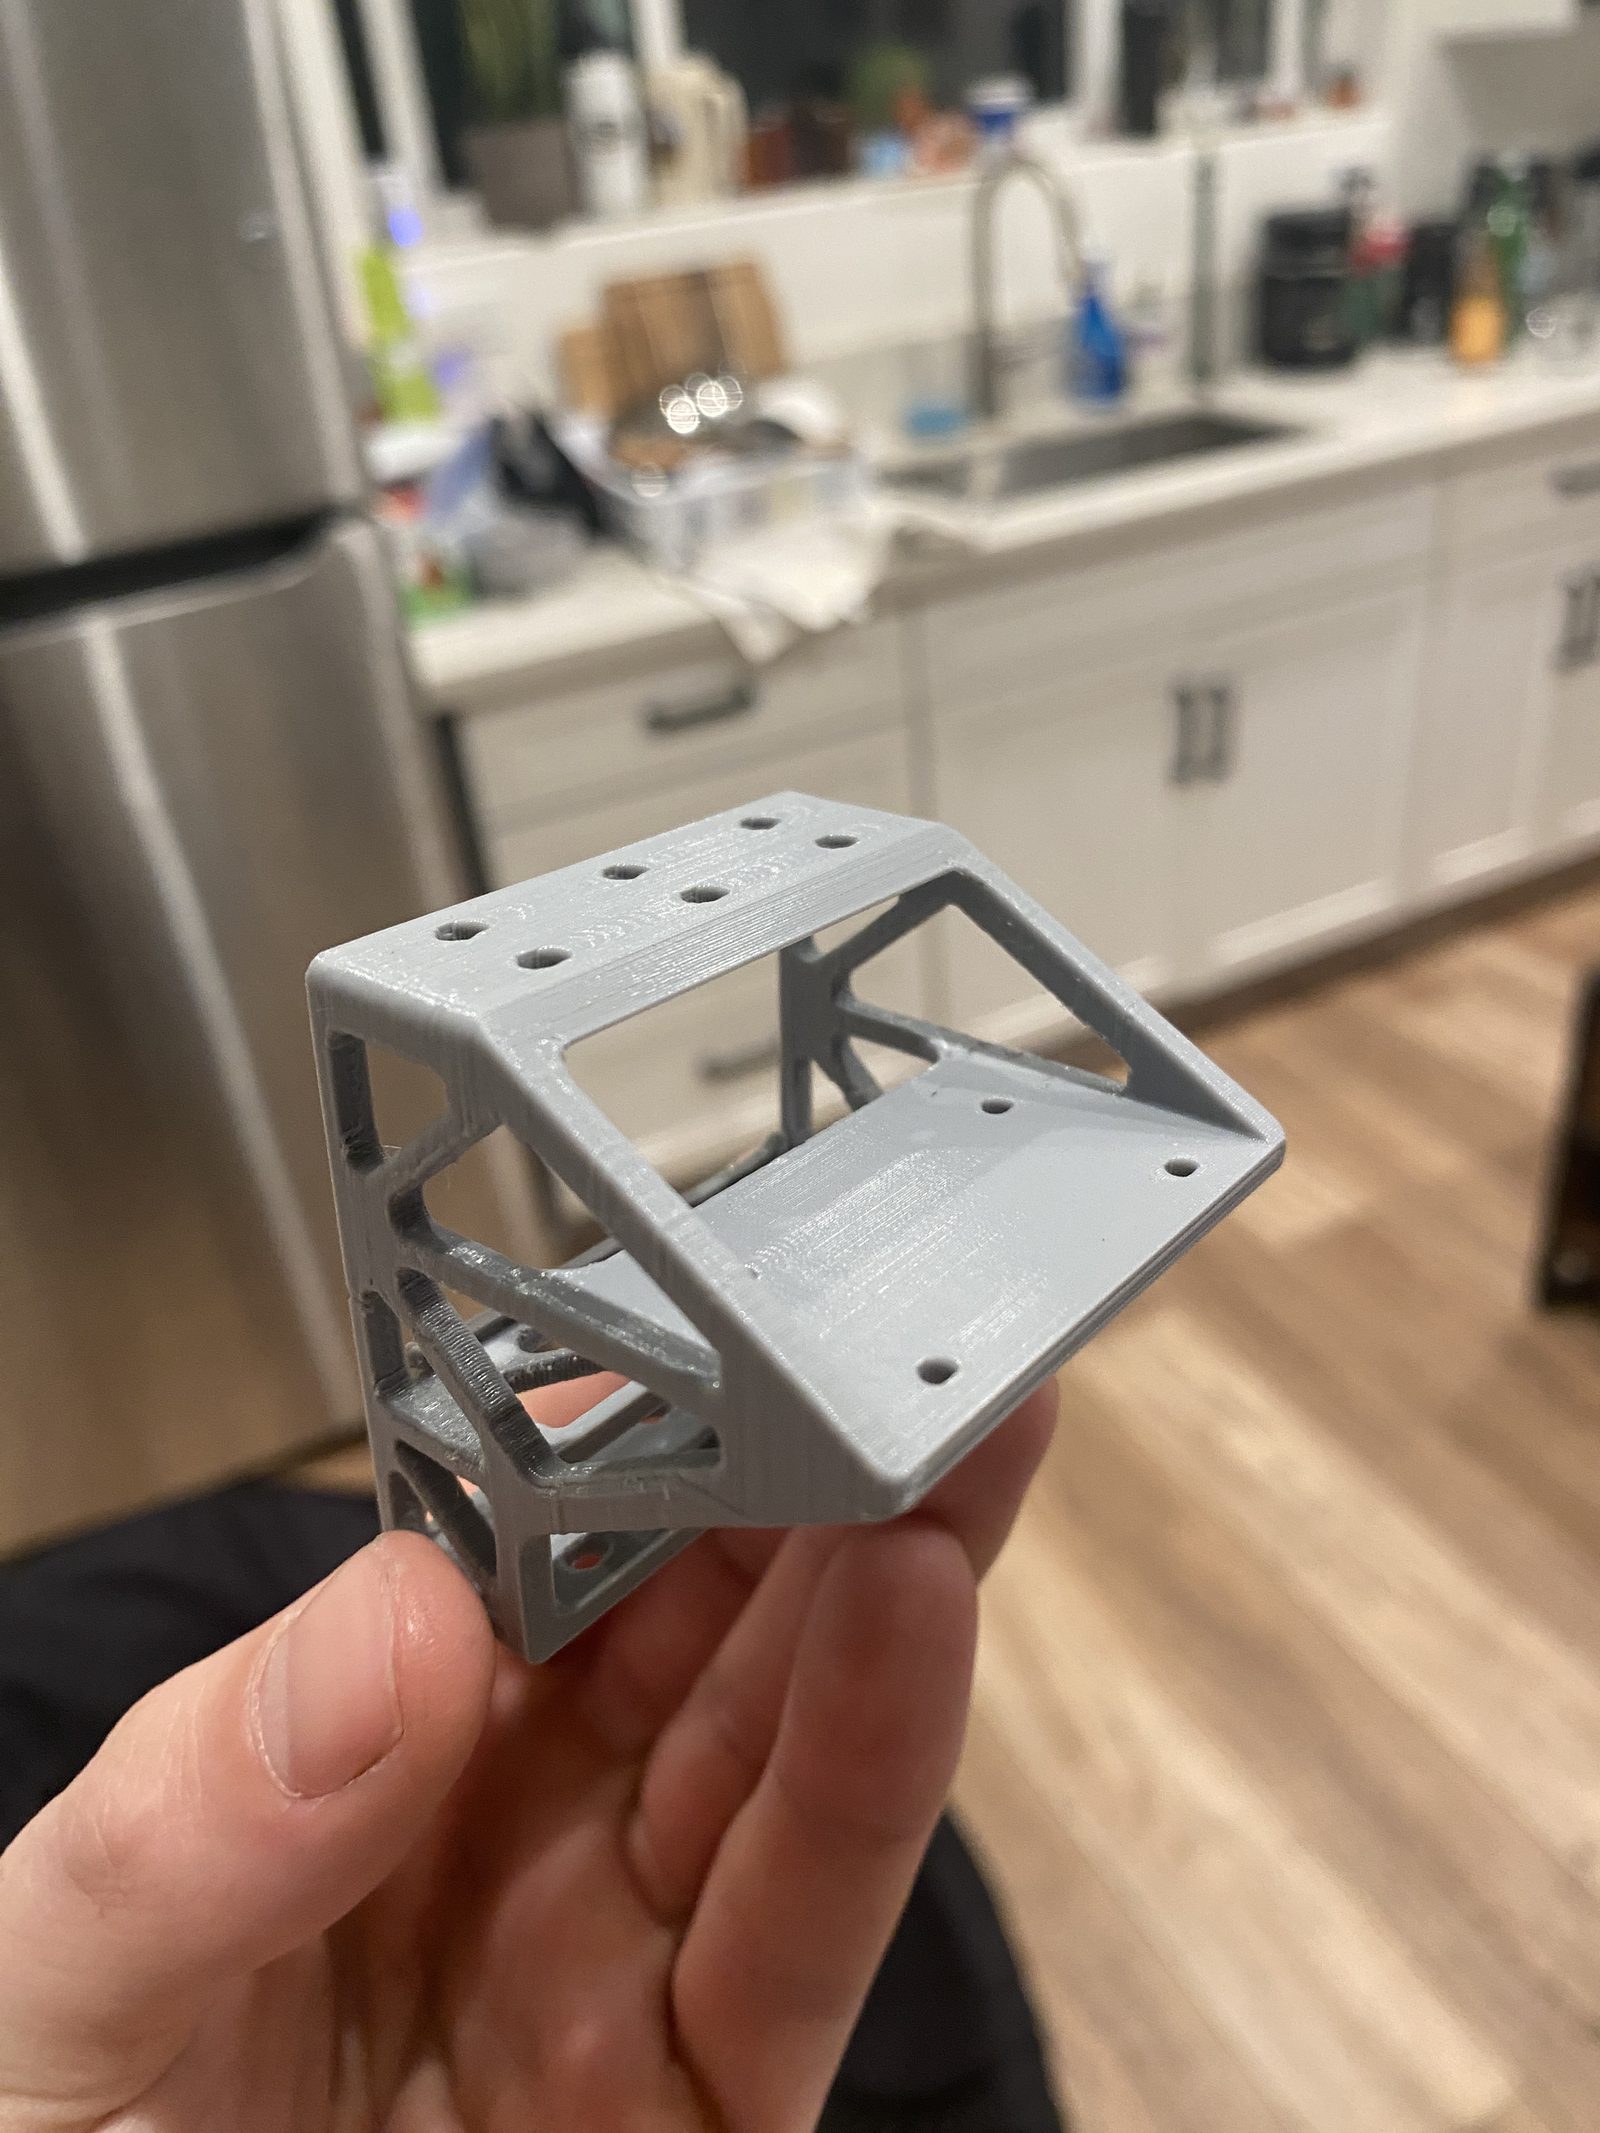
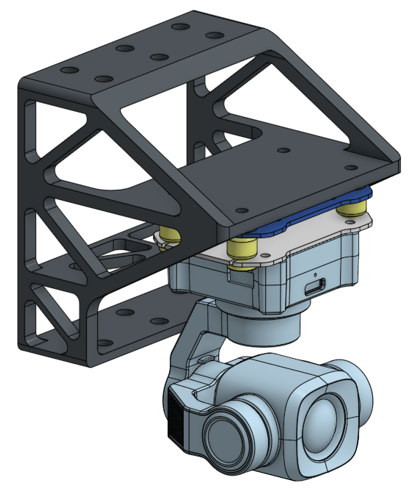
Mk4 is 45% lighter than Mk1, with 0.00003 in modeled deflection at nominal load. Designed in Onshape: a 3D-printed mount and camera cover for Osiris, the Cal Poly C-UAS quadcopter, replacing an aluminum plate mount. Printed in PPA-CF (carbon-fiber nylon), where stiffness governs over strength, and tuned from Mk1 to Mk4 with Abaqus FEA. The mount was printed; deflection is from FEA only.
| Load case | Max deflection, in | Bulk von Mises, ksi |
|---|---|---|
| Worst case, overestimated payload | 0.00125 | 5, against 24 yield |
| Nominal | 0.00003 | not reported |