FIRST Robotics: FTC and FRC Robot Design
Competed
Designed and machined FTC 15281's 2018-19 robot: a 4-degree-of-freedom (4-DOF) arm that scored game elements into the lander, and a latch that raised and lowered the 30 lb robot. Design lead on FRC 6831 from 2020 to 2022.
My role.Designer and machinist. Did most of the programming, integration, and fabrication; the build team was mostly one teammate and me.
FTC 15281 robot
In the 2018-19 Rover Ruckus game, robots scored minerals into a lander and, at the end of the match, latched onto the lander and hung from it.
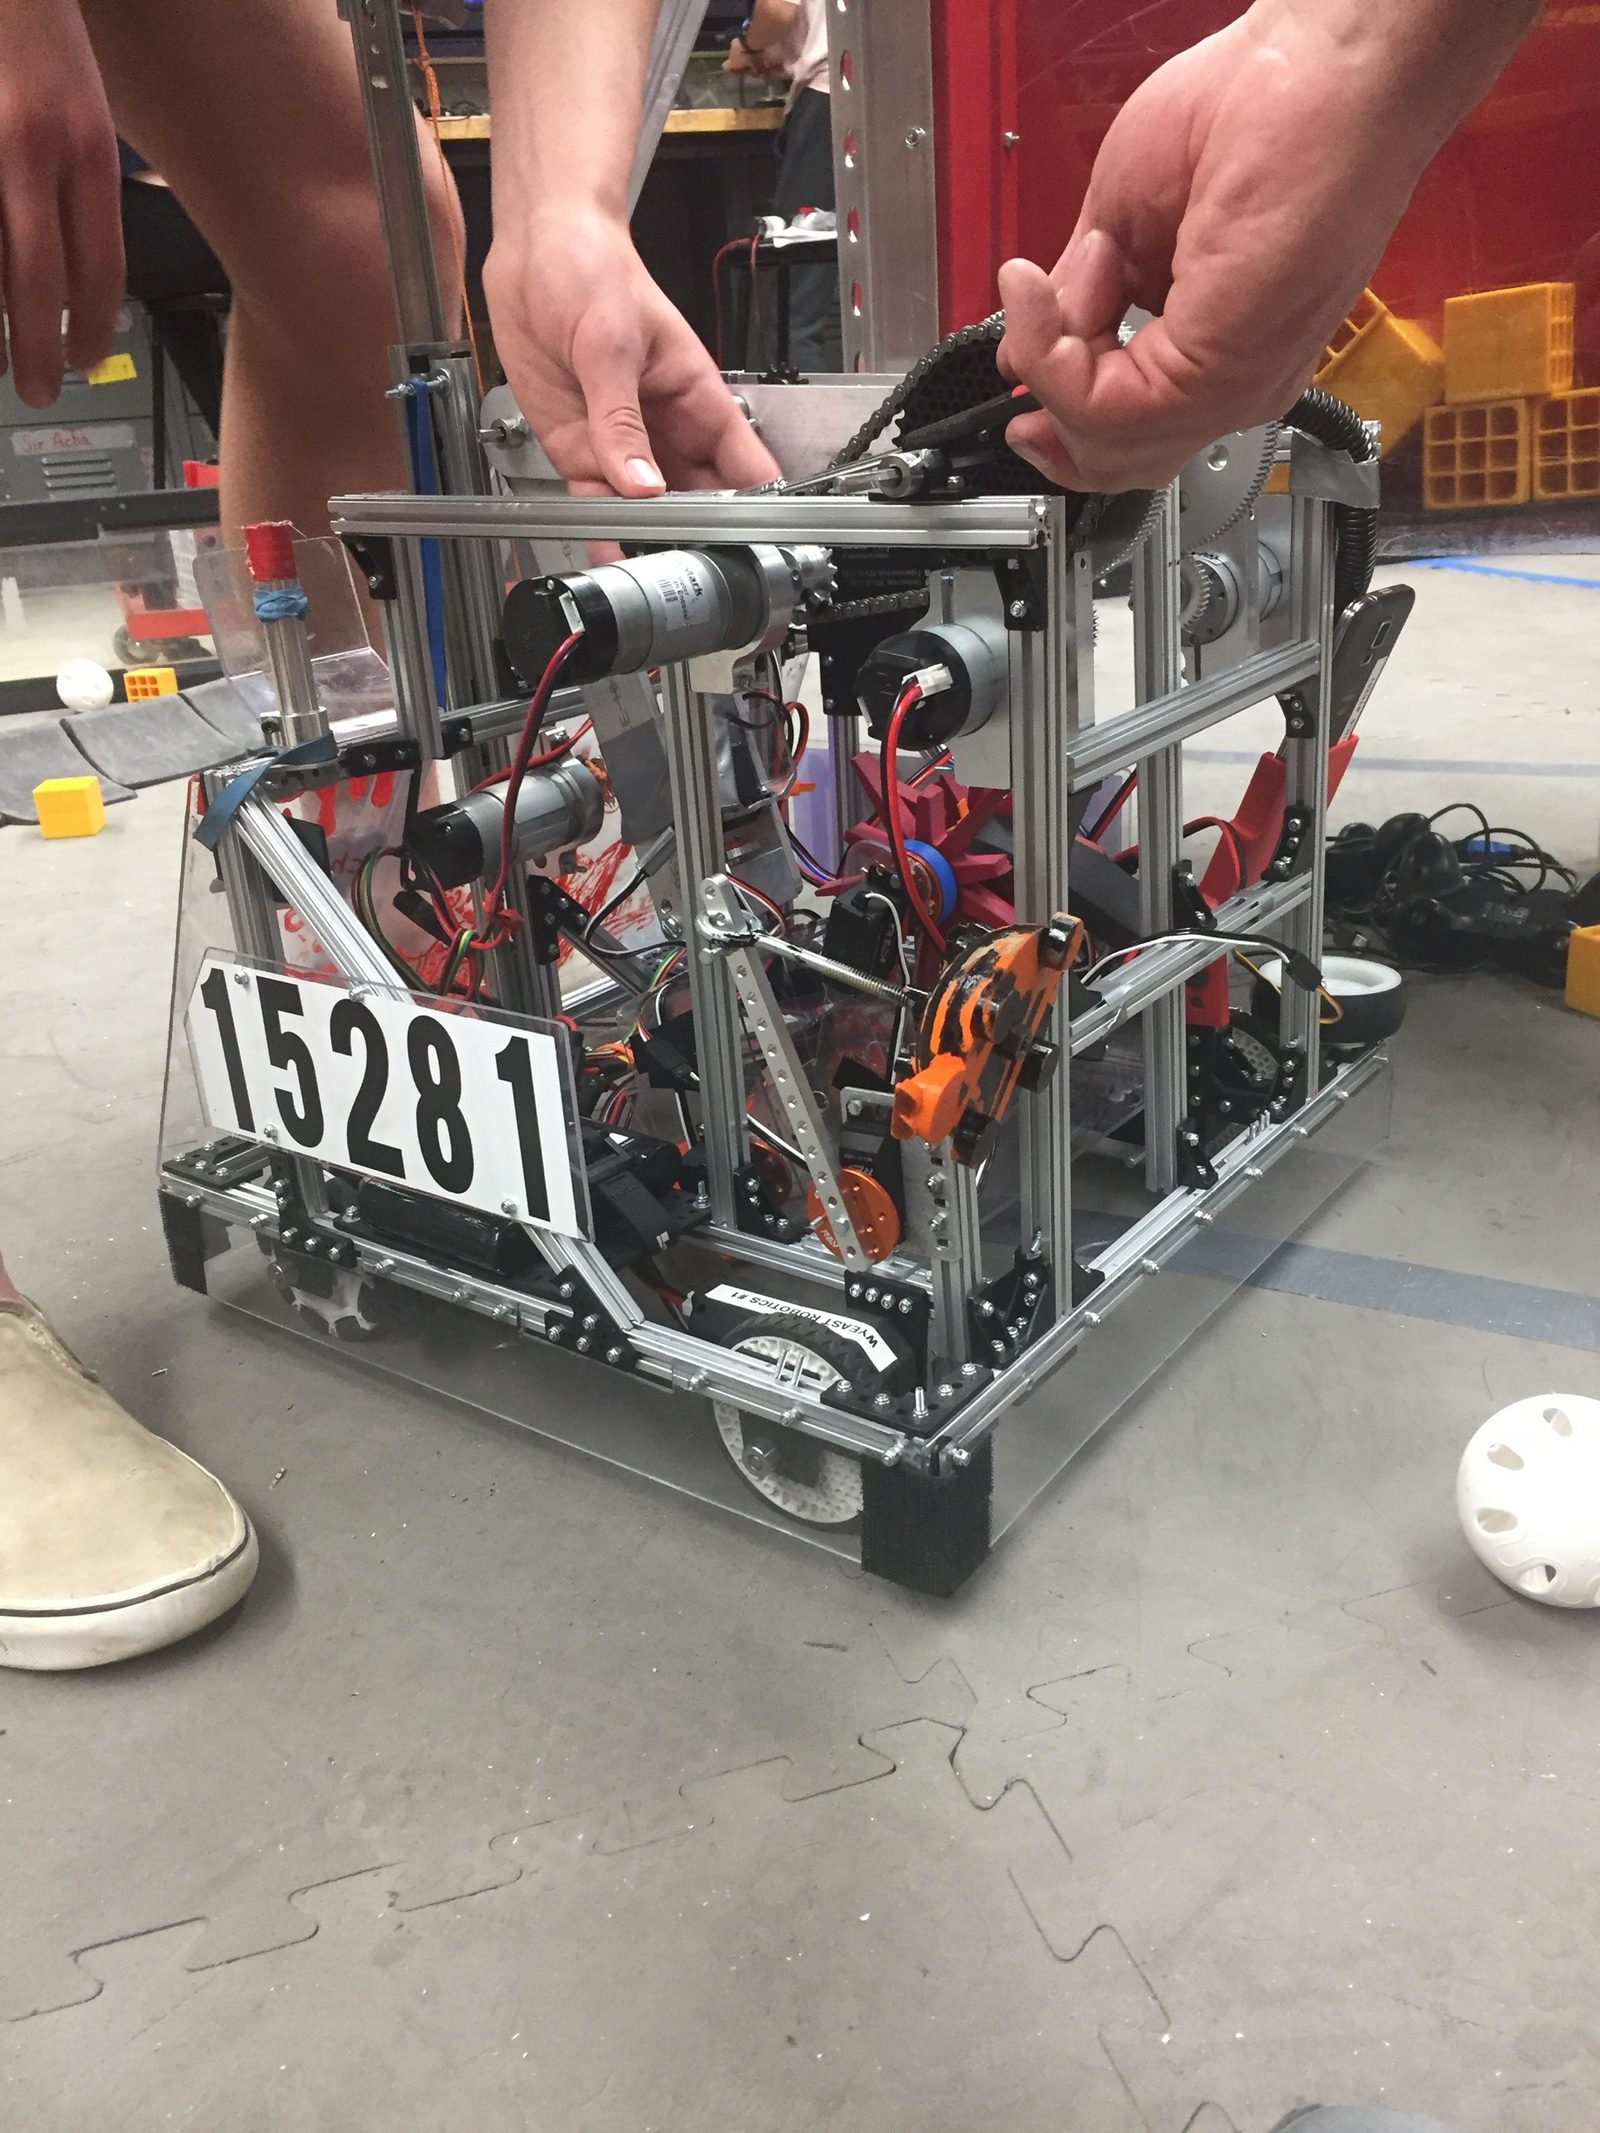
Added servo-driven intake and eject at the end of the arm, a fifth driven axis.
Failure mode: the arm failed under its own torque, from the robot's center of gravity combined with the arm's torque on a long lever. New gear ratios fixed it.
FTC 8176 shooter
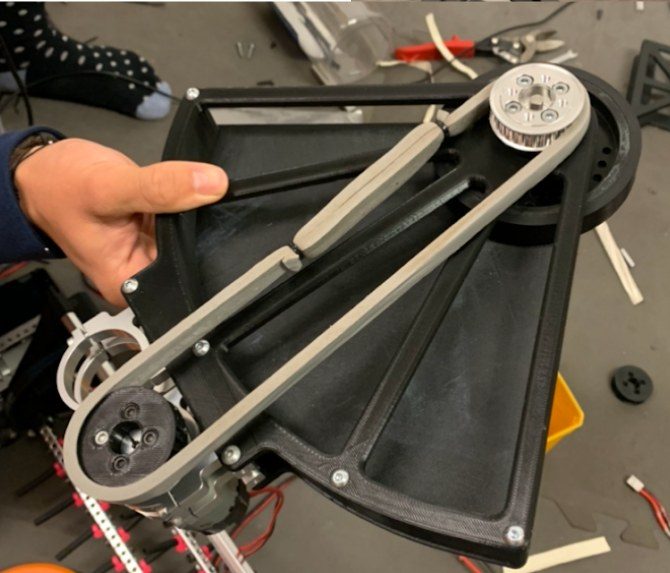
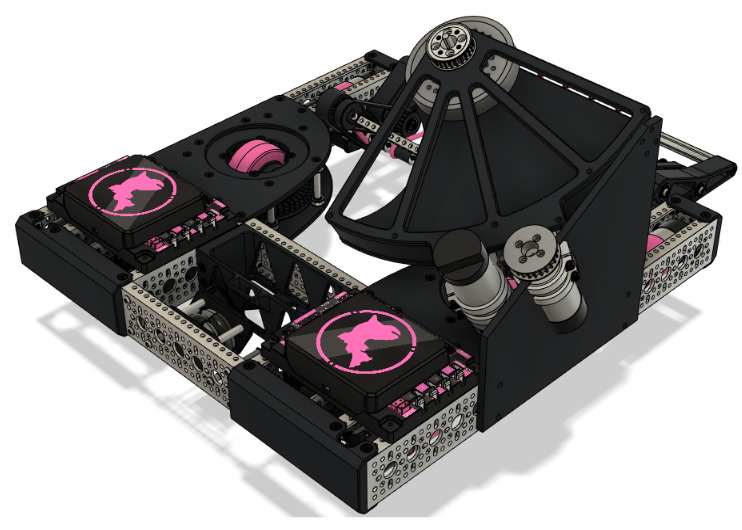
J-shooter for FTC 8176 Steelhead, 2020-21. The Ultimate Goal game required shooting foam rings into high goals and power shots from varying distances. The launcher had to be compact, serviceable, and fit a differential swerve drivetrain.
Contributions
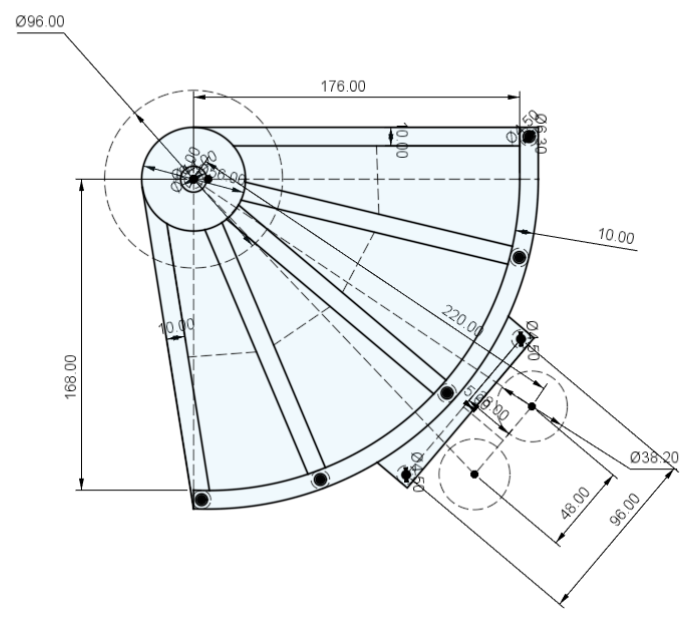
- Designed a curved ring path, adapted from FRC shooters, that guides each ring around a flywheel before release for more contact time
- Modeled it parametrically in CAD: flywheel placement, ring compression, and mounting; bearing-supported shafts, timing belt drives, standard hardware, and many 3D-printed parts
- Evaluated linear belt-driven and flywheel-only concepts; the belt-driven concept had friction and ring slippage
- Built a prototype on a test chassis; testing showed sensitivity to ring guidance and ramp geometry, so I refined ring alignment, transition surfaces, and compression
Team result: Inspire Award 3rd place, 2021 Oregon State Championship.
Other teams
- FTC 4143 Mocha, 2019-20: designed the robot
- FRC 6831 A05 Annex, 2019 to 2022: team member, then design lead from 2020 to 2022